

M1 Wheeled Dual-arm Robot
M1 integrates an omnidirectional mobile base, an 800 mm lift, dual-arm manipulation and multi-camera perception into one platform for compound tasks in industry, research and service settings.
Explore M1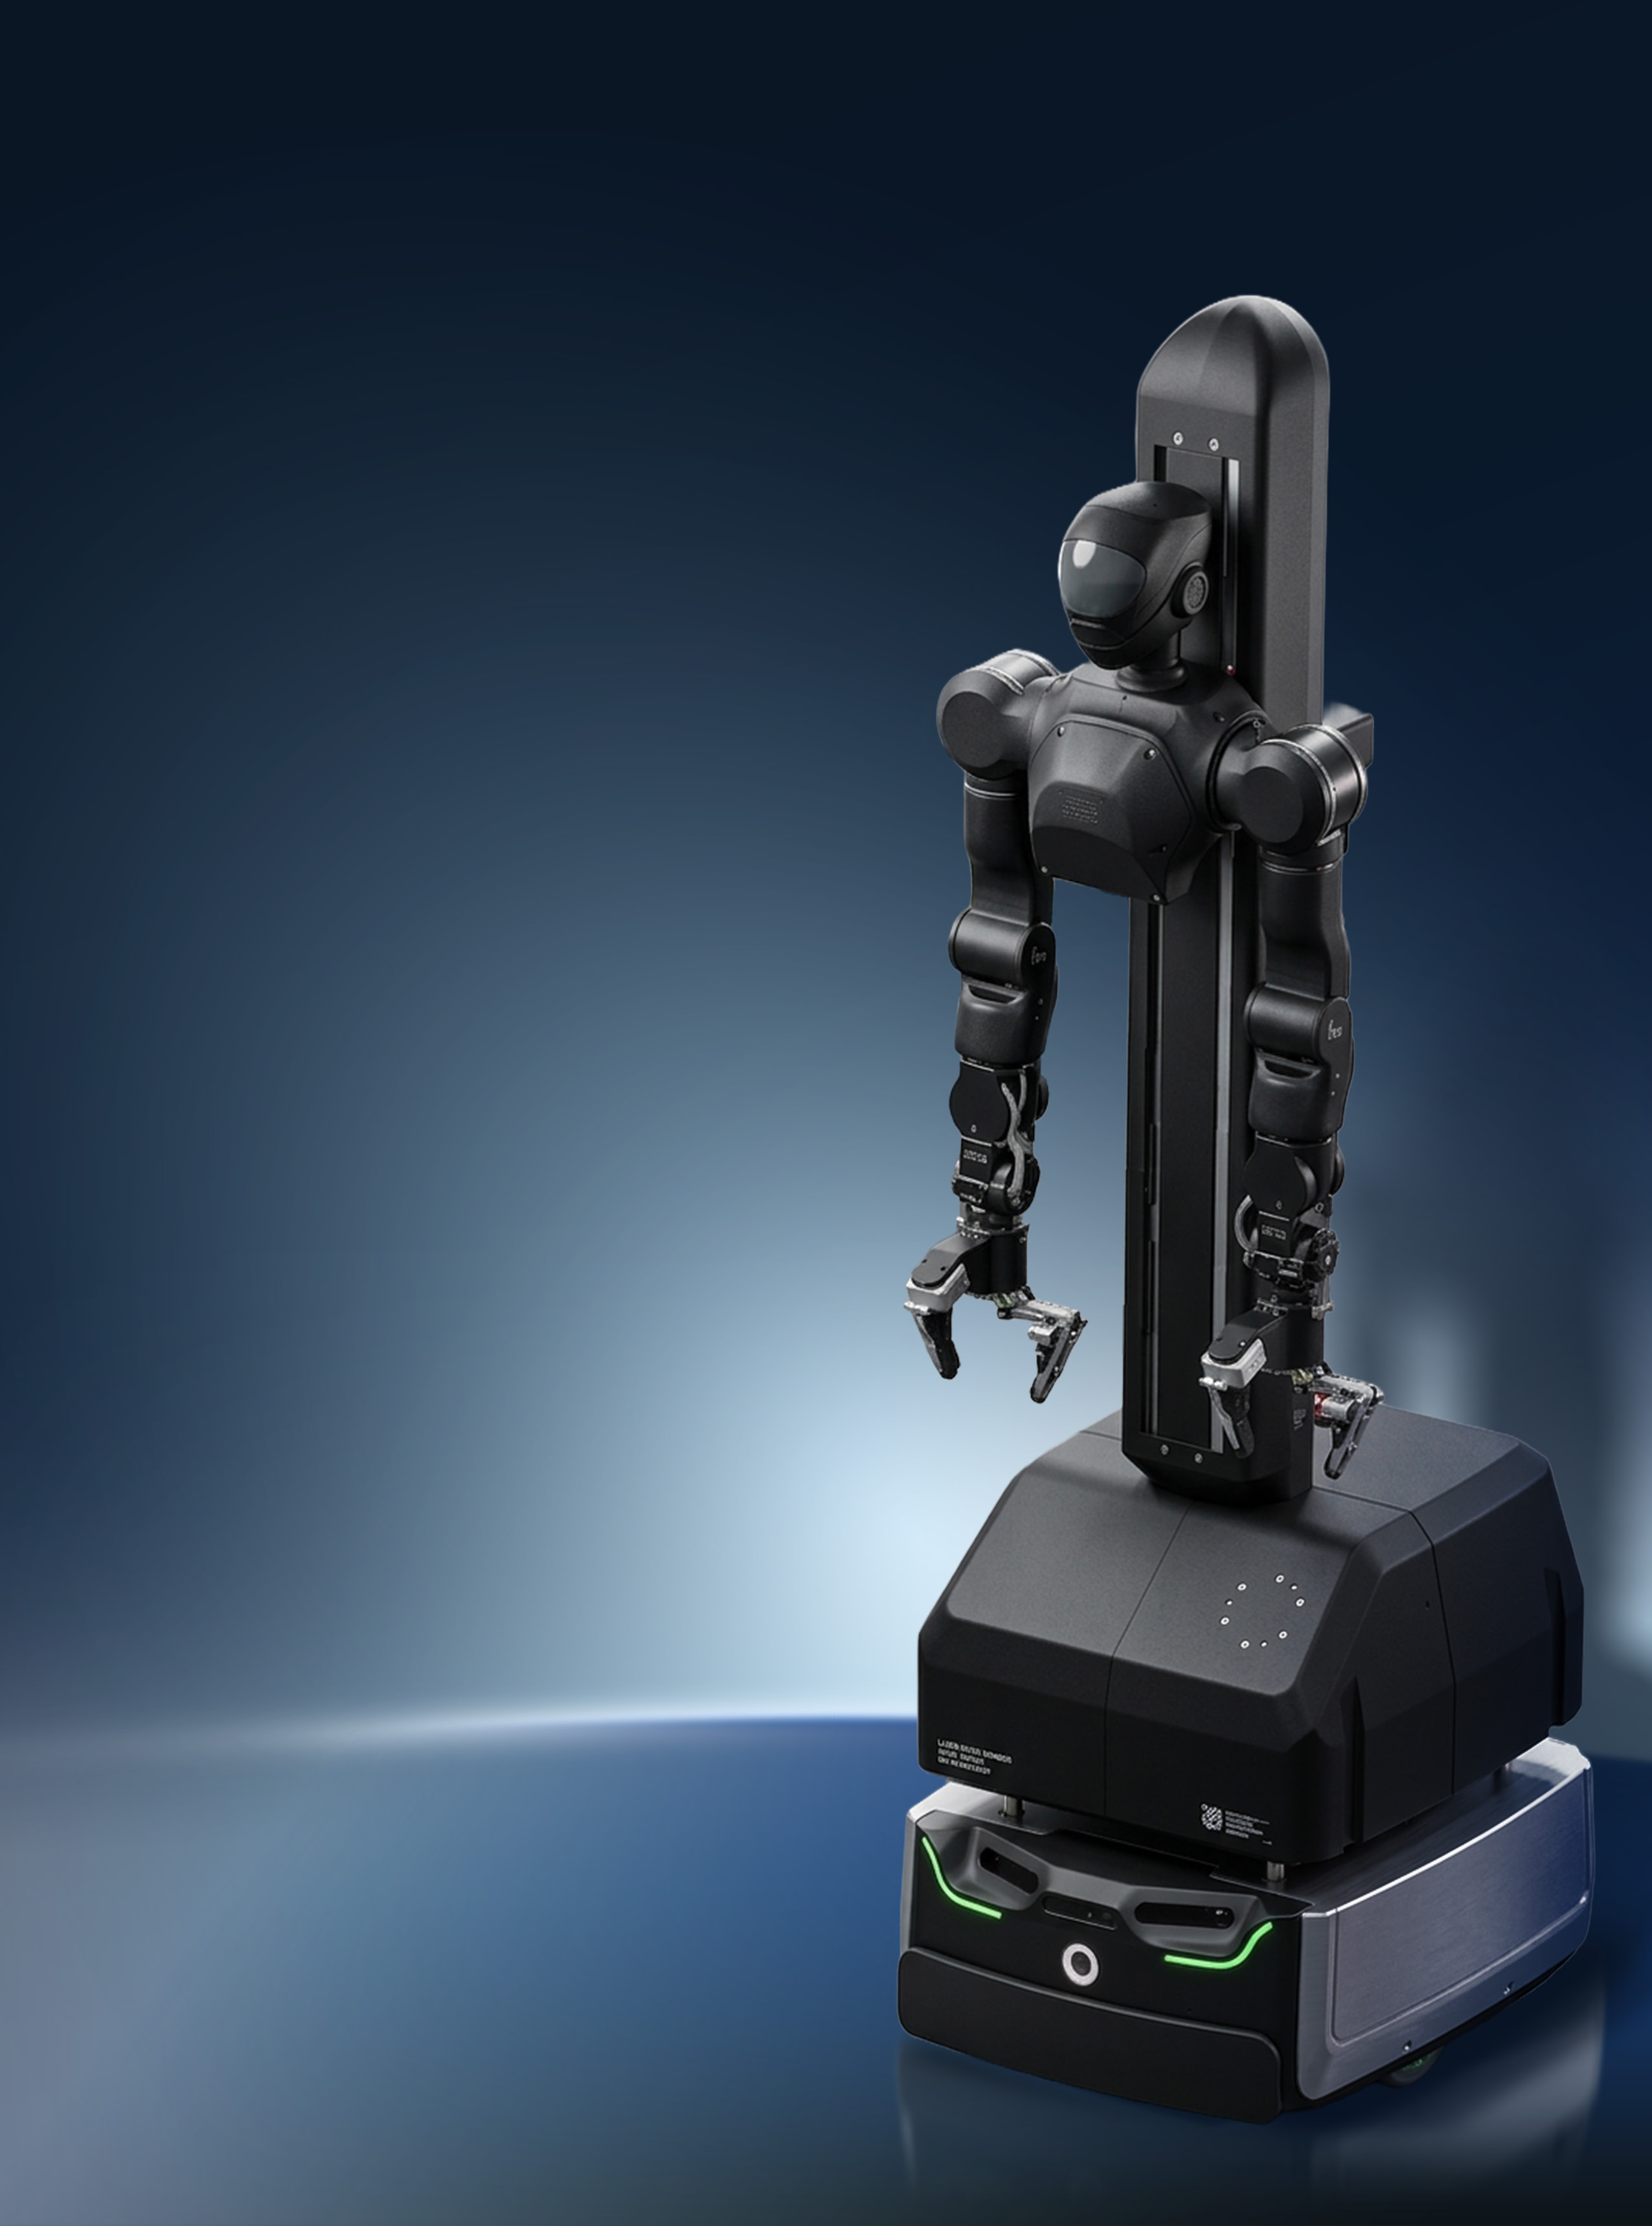
The current portfolio includes the M1 wheeled dual-arm robot and three dexterous-hand directions.
 人形机器人
M1 integrates an omnidirectional mobile base, an 800 mm lift, dual-arm manipulation and multi-camera perception into one platform for compound tasks in industry, research and service settings.
 灵巧手
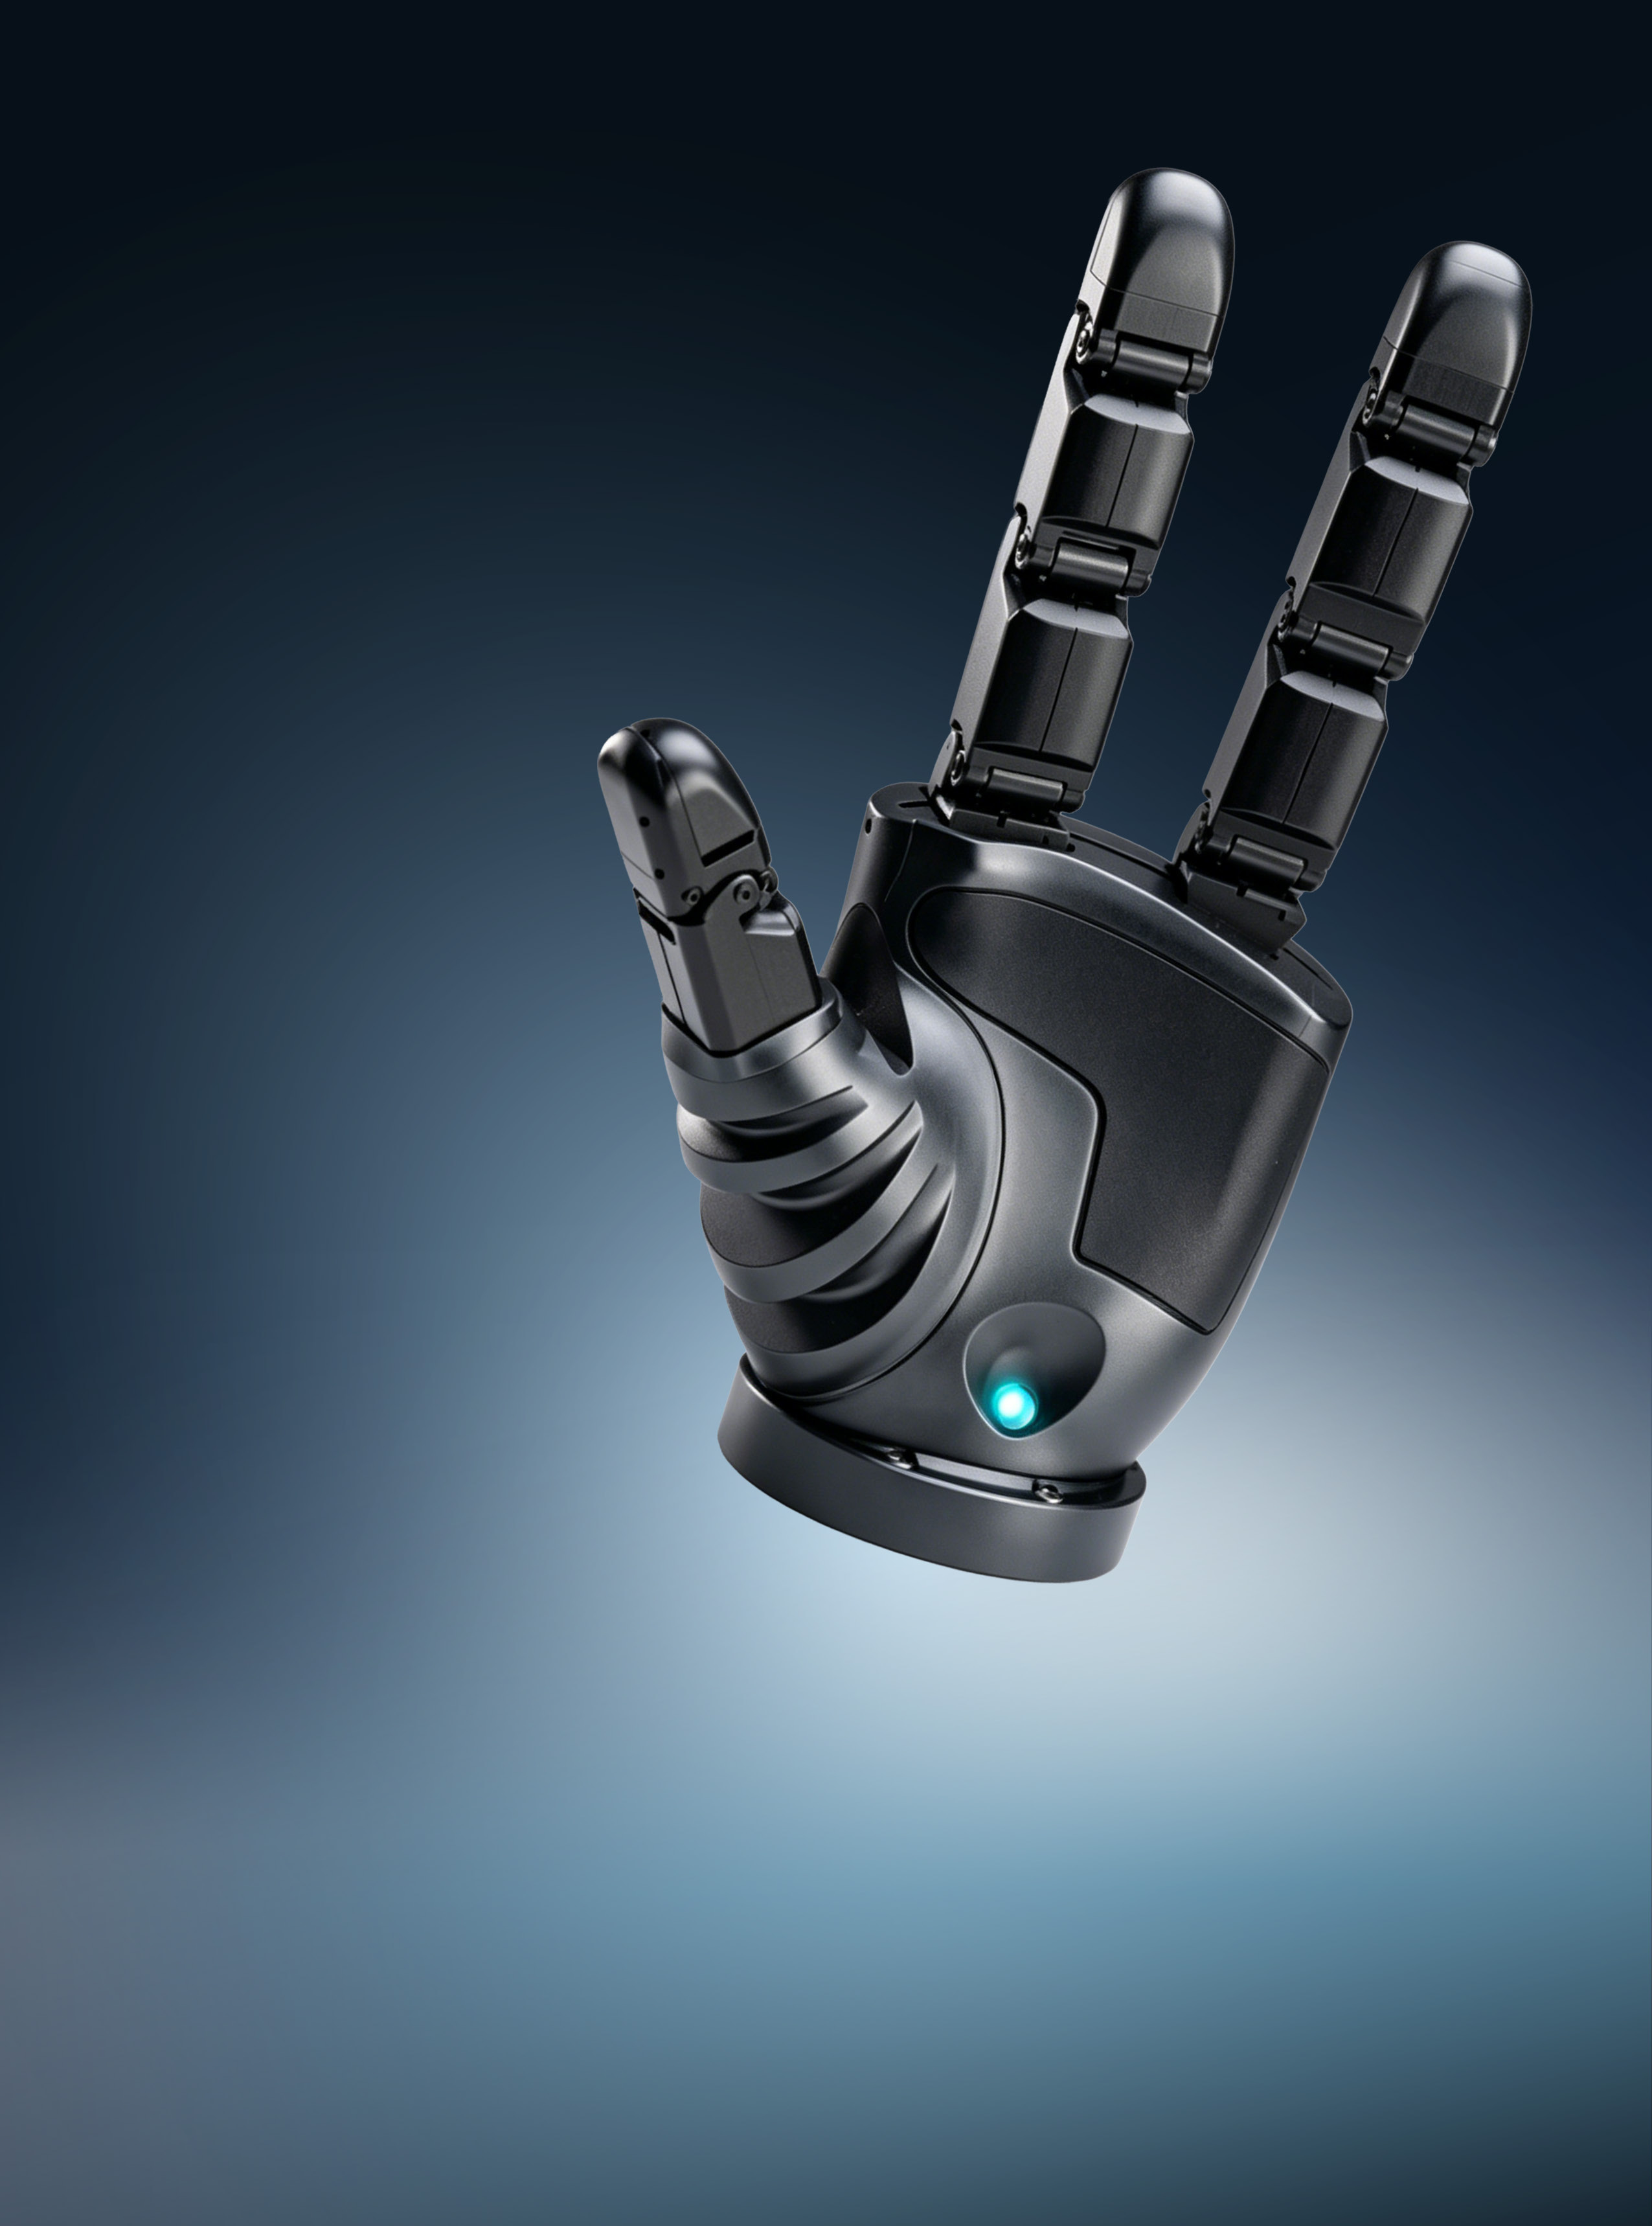
Twelve degrees of freedom work with a three-layer force-control loop in a compact body for precision pinching, planar clamping, opposed grasping, side clamping and precision insertion.
 灵巧手
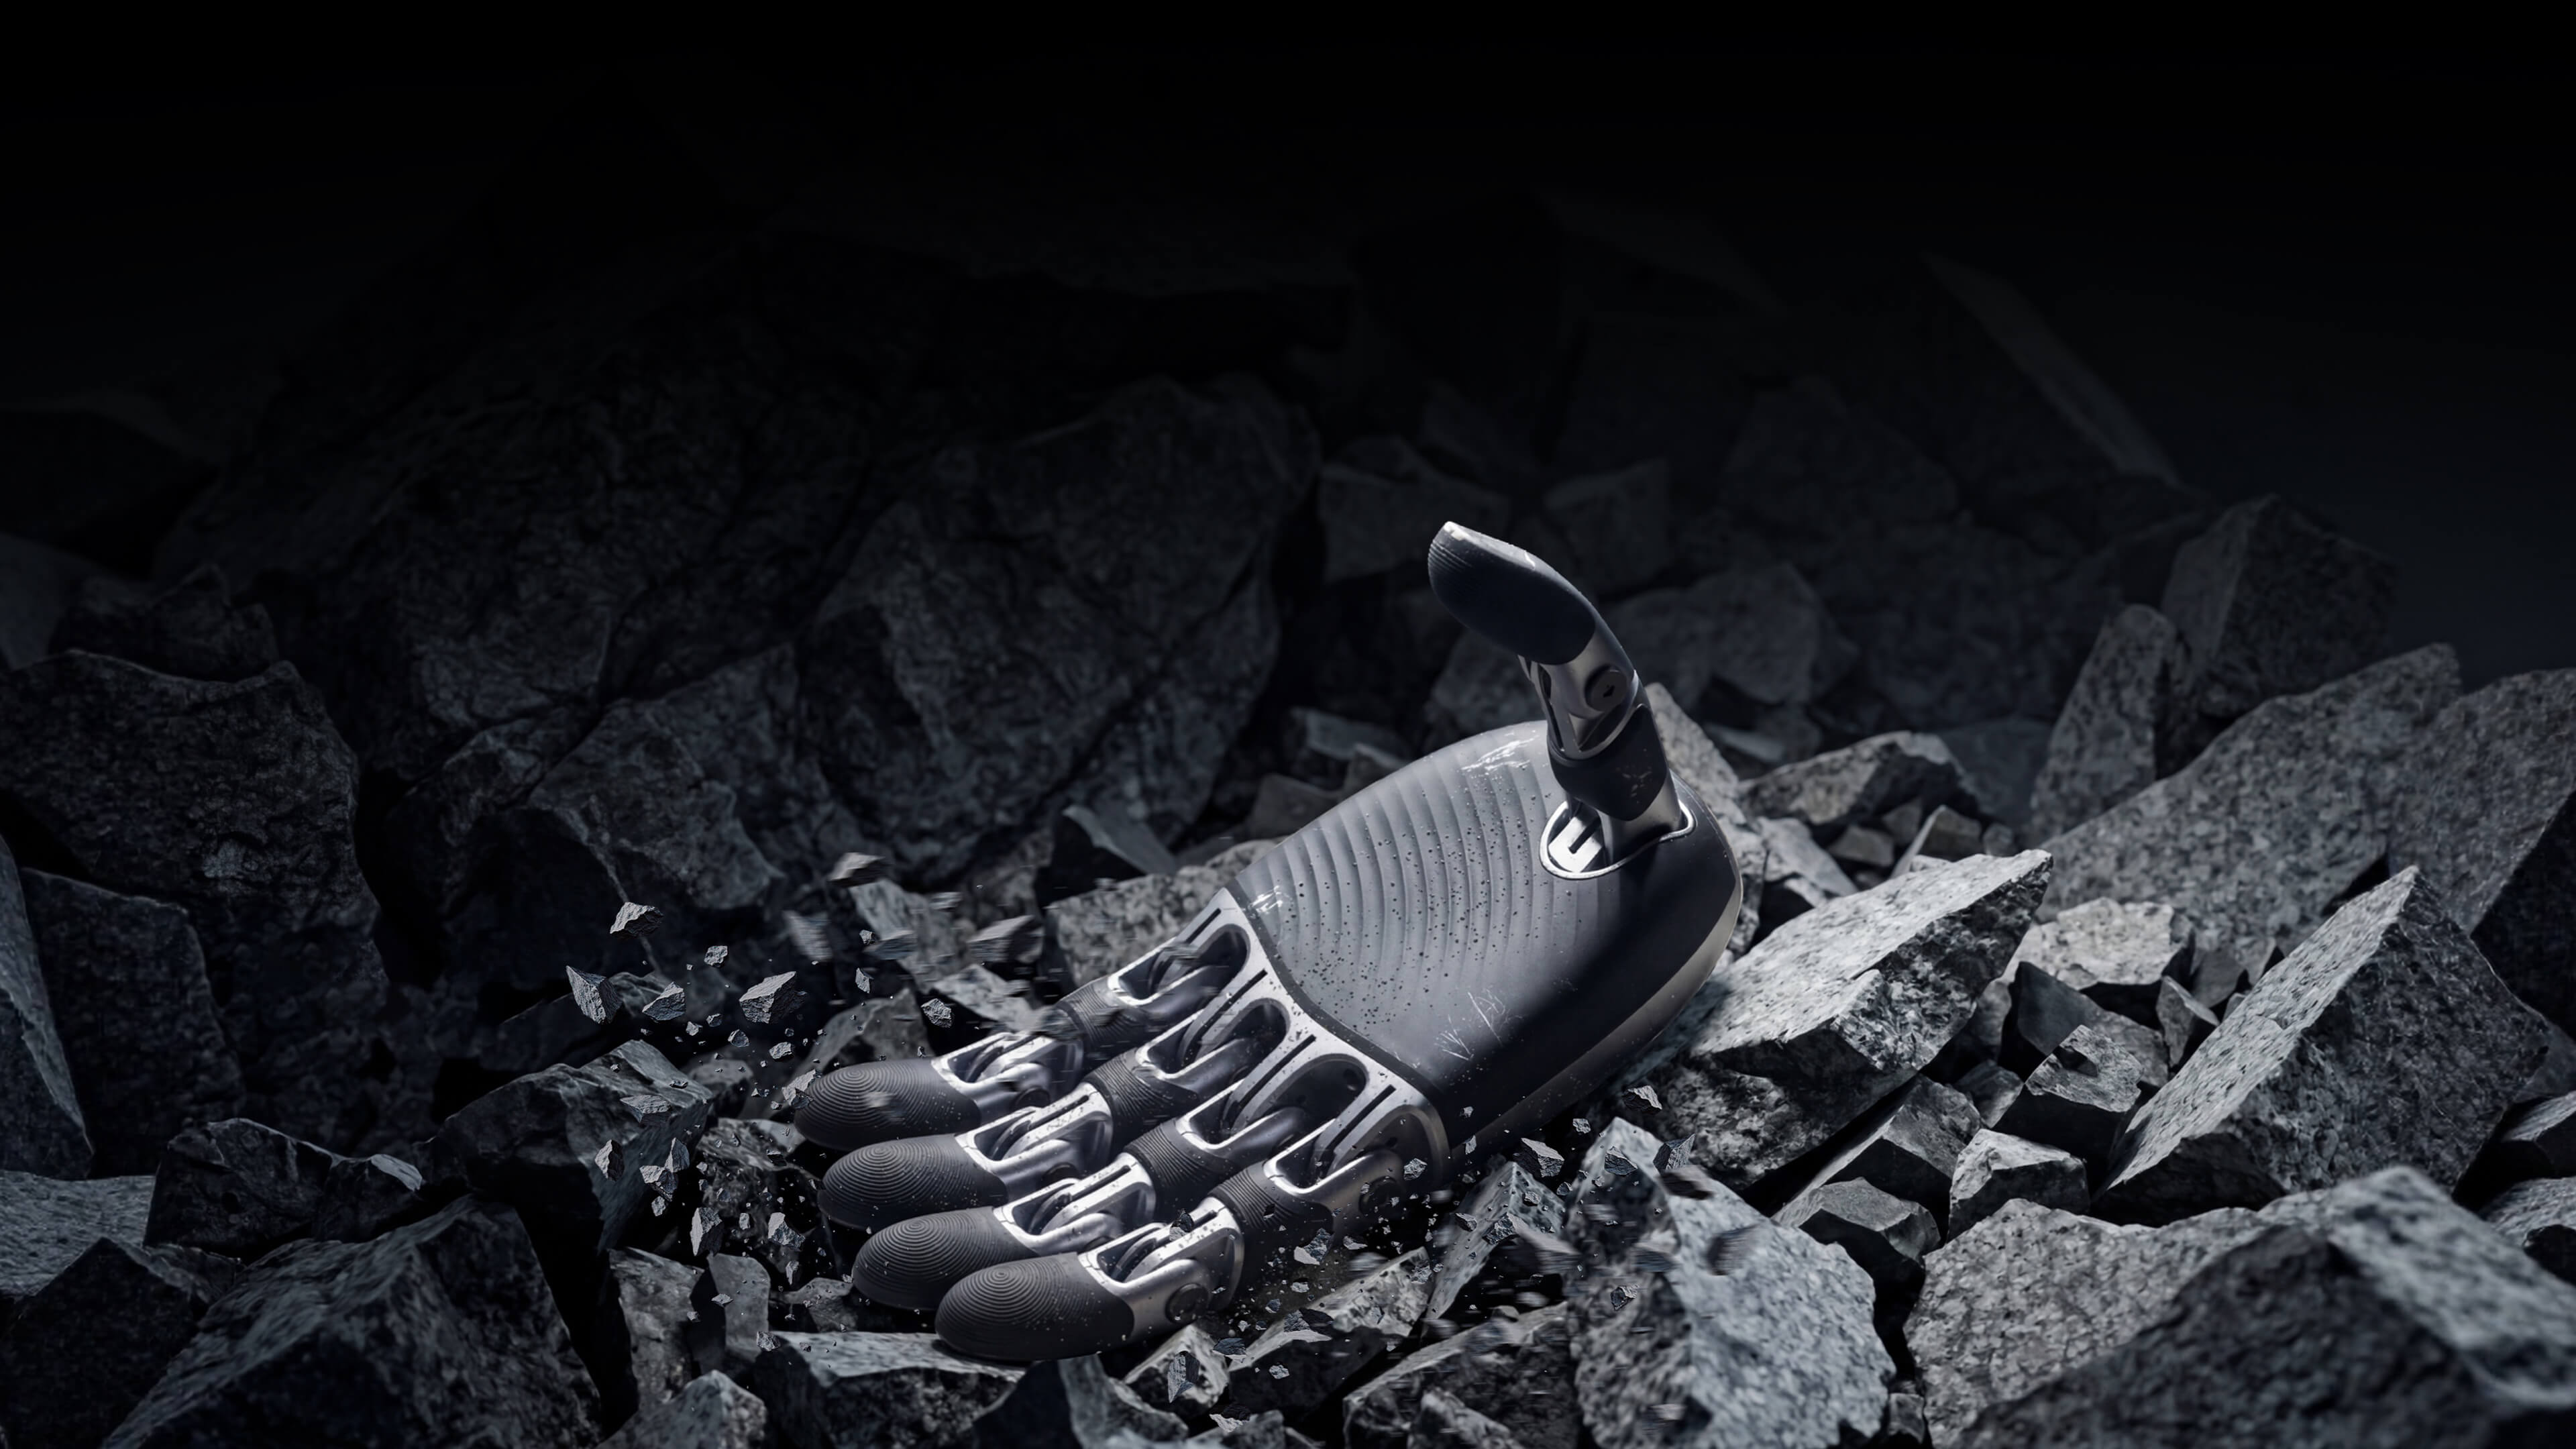
Four parallel grasping fingers and one opposed thumb create a natural anthropomorphic workspace, built around twenty DOFs, multimodal tactile sensing and real-time software interfaces.
 灵巧手
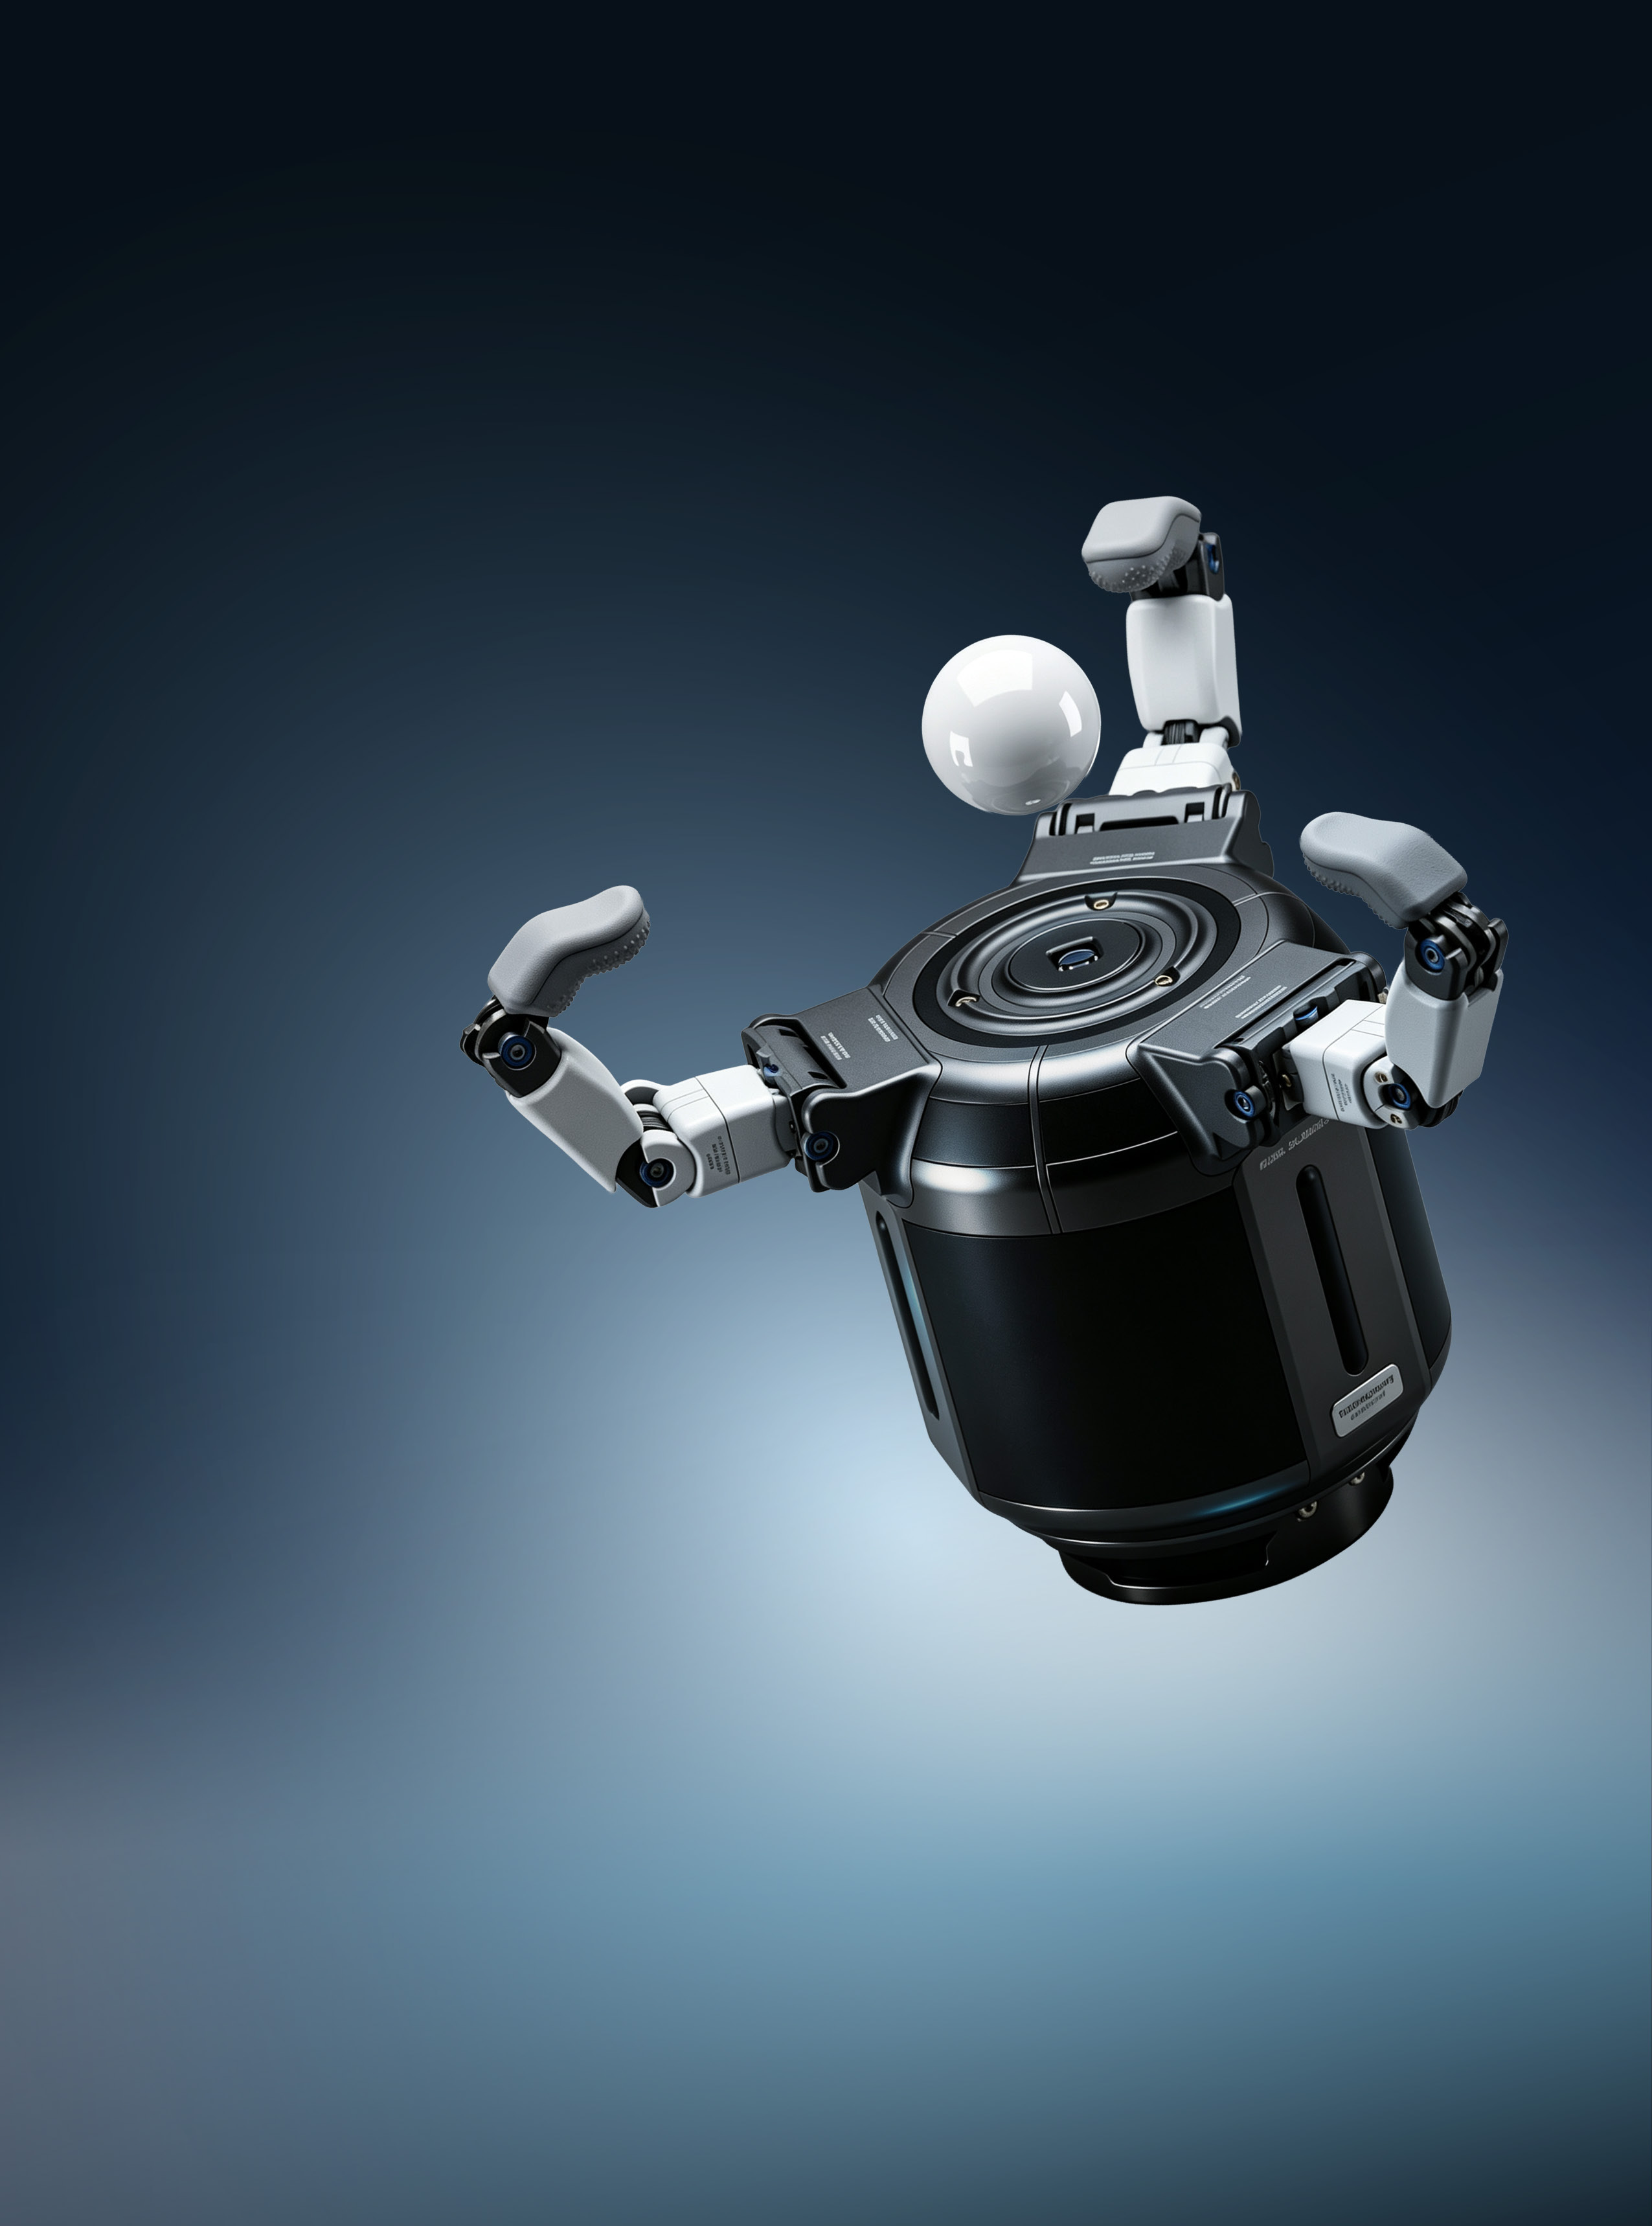
A symmetric 120° three-finger layout with three joints and four DOFs per finger balances multi-DOF motion and flexible grasping through tendon drive.
M1 provides mobility, perception and a dual-arm platform. Dexterous hands provide task-specific end effectors.
M1 integrates an omnidirectional mobile base, an 800 mm lift, dual-arm manipulation and multi-camera perception into one platform for compound tasks in industry, research and service settings.
Explore M1Twelve degrees of freedom work with a three-layer force-control loop in a compact body for precision pinching, planar clamping, opposed grasping, side clamping and precision insertion.
Explore dexterous handsStart with degrees of freedom, force-control performance and task direction, then open a product for full specifications.
| Product | Degrees of freedom | Force resolution | Weight | Positioning / Grasping |
|---|---|---|---|---|
| Three-finger Fully Actuated Force-control Hand | 12 DOF | ≤0.1 N | ≤500 g | 0.5–50 N |
| Five-finger Fully Actuated Force-control Hand | 20 DOF | ≤0.1 N | — | 0.5–50 N |
| Three-finger Tendon-driven Dexterous Hand | 12 DOF | — | ≤950 g | ±0.5 mm |