

Total DOF
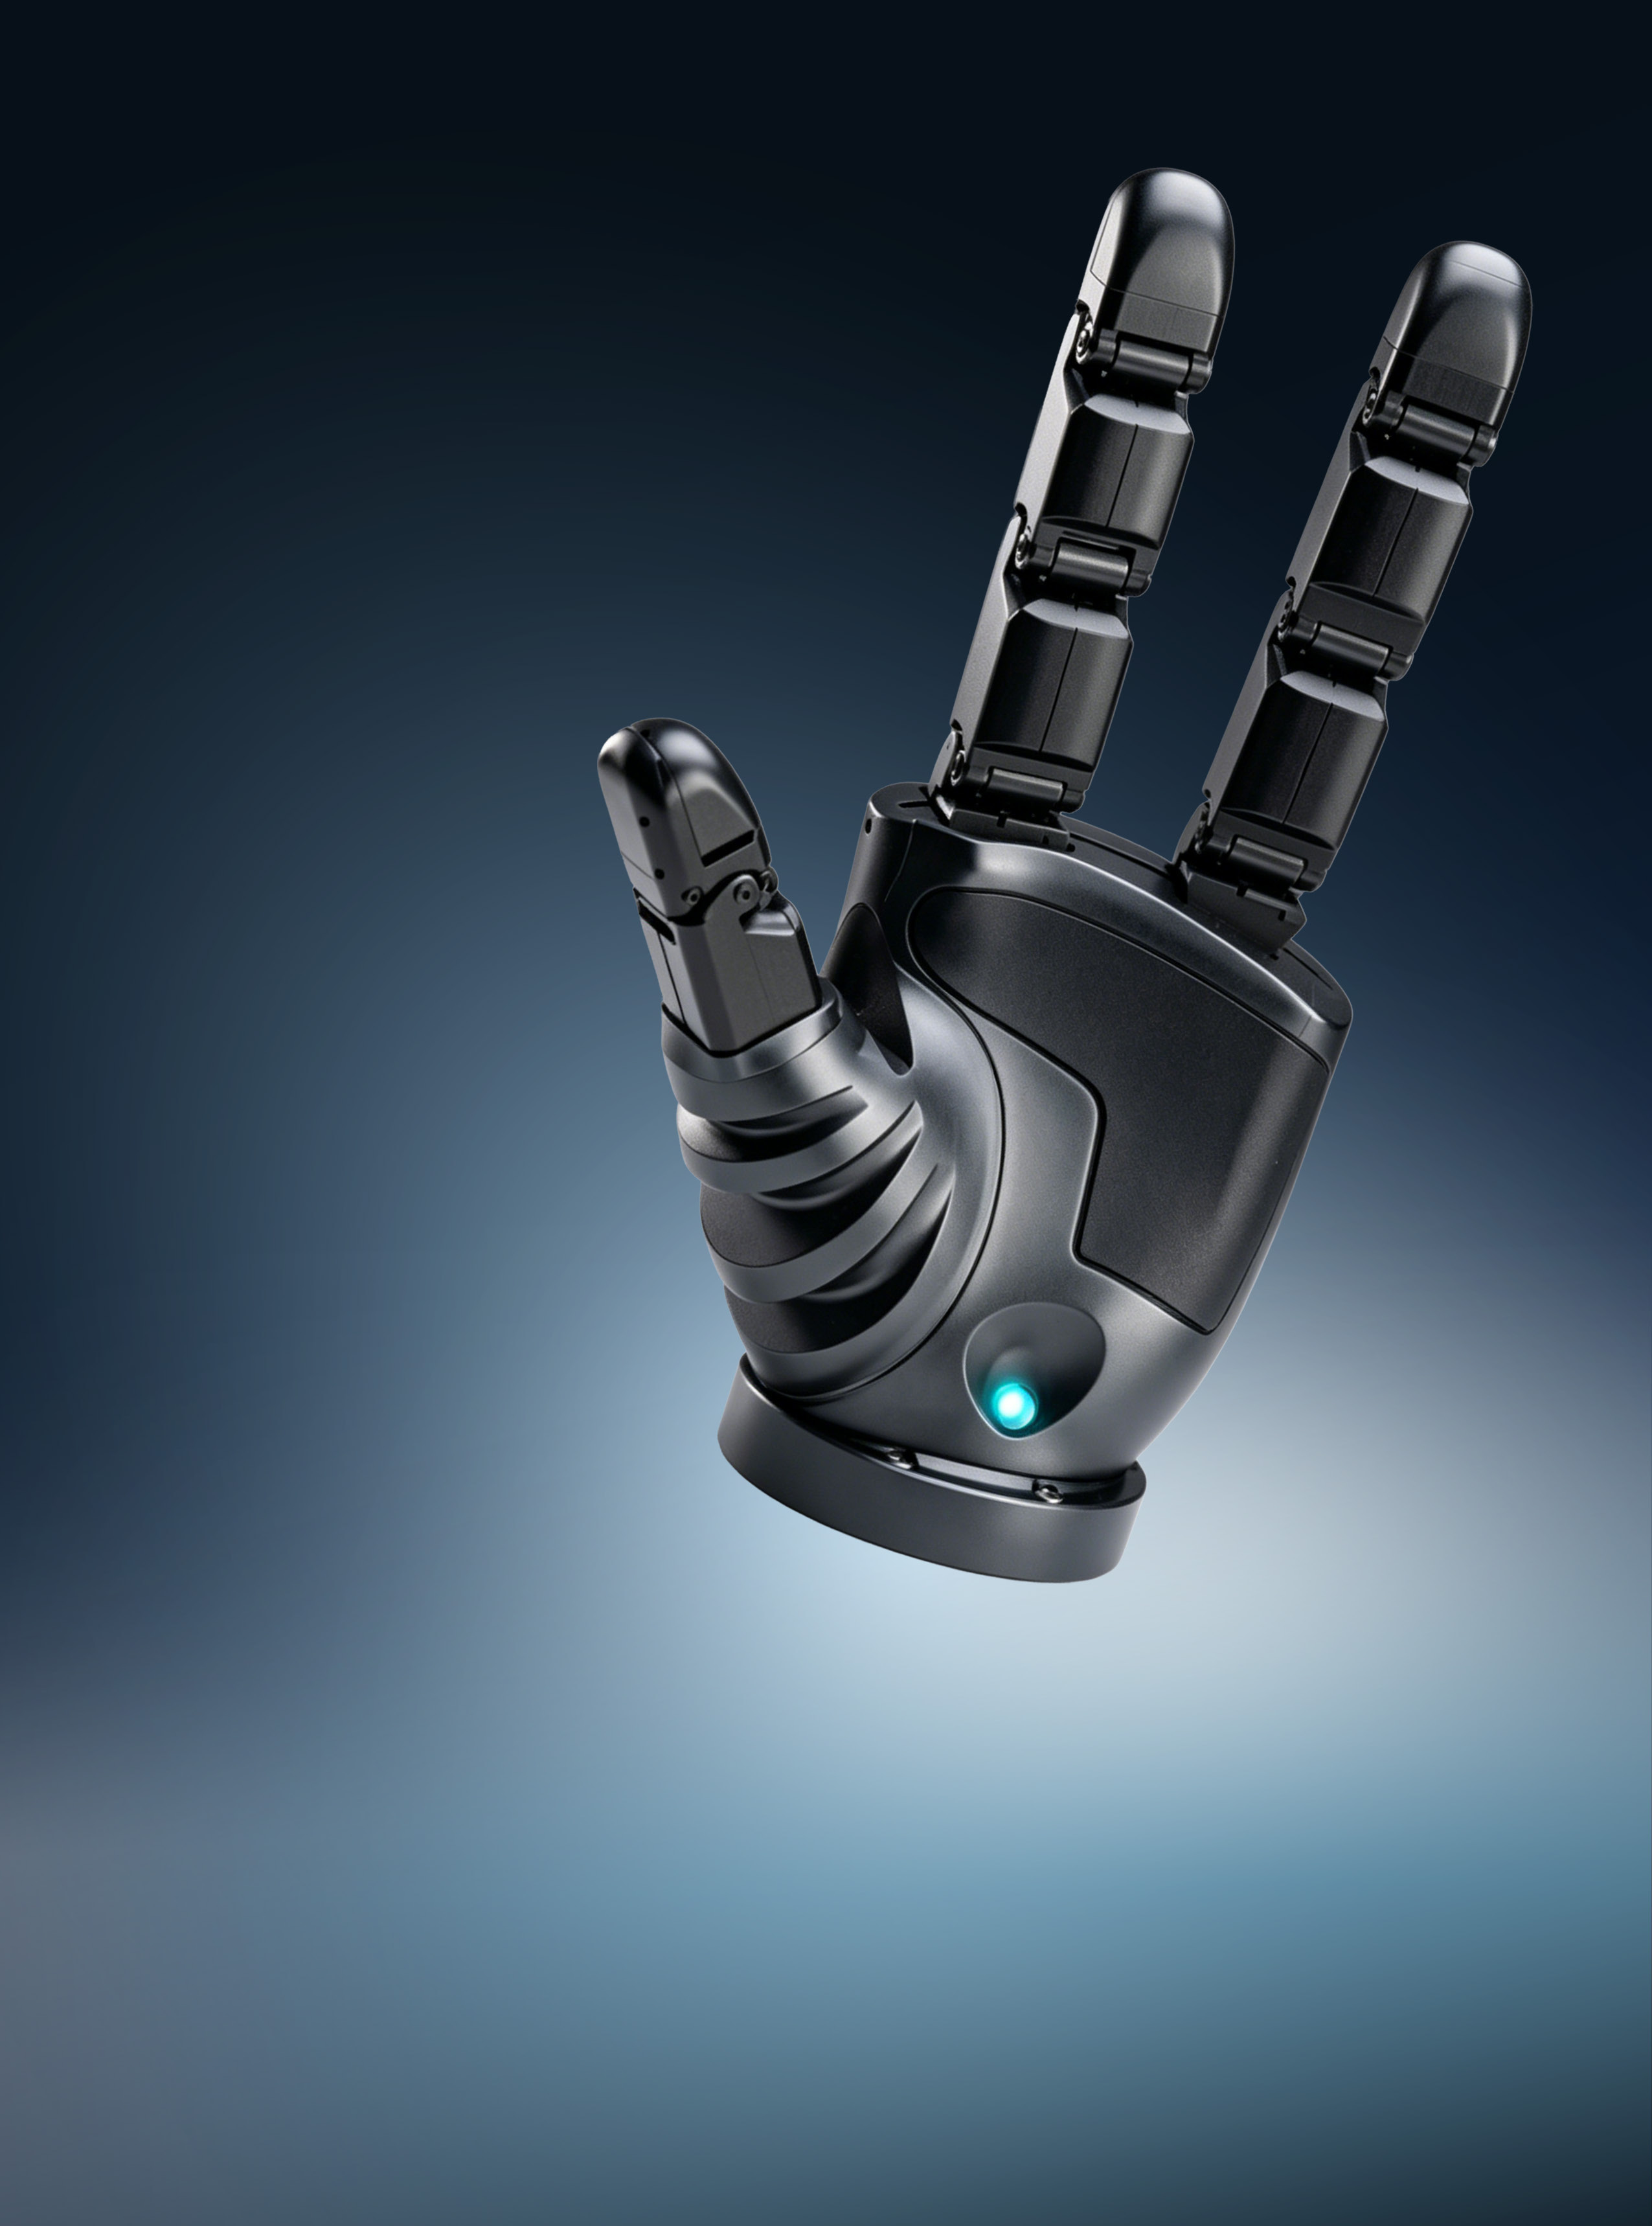
灵巧手
Three-finger Fully Actuated Force-control Hand
An industrial fully actuated force-control end effector for precision assembly and flexible grasping.
Fingertip force resolution
Torque response
Peak force per finger
PRODUCT CAPABILITY
Three-finger Fully Actuated Force-control Hand
Control every contact with confidence.
The hand is built around twelve degrees of freedom, multimodal sensing and real-time software interfaces for precision assembly and flexible grasping.
Core capabilities:
- Three-layer force loop: joint, grasp and task-level control work together.
- Multimodal sensing: fingertip, finger-pad and palm tactile sensing with palm vision.
- Precision motion: fingertip repeatability ≤±0.05 mm.
- Open development: ROS 2, C++, Python and Modbus support.
TECHNICAL SPECIFICATION
Technical specifications
All specifications come from the currently supplied product spreadsheets and PDFs.
Specifications
- Total DOF
- 12 DOF
- Fingertip force resolution
- ≤0.1 N
- Torque response
- <5 ms
- Peak force per finger
- 50 N
- Hand weight
- ≤500 g
- Grasp-force range
- 0.5–50 N
RELATED PRODUCTS
Related products
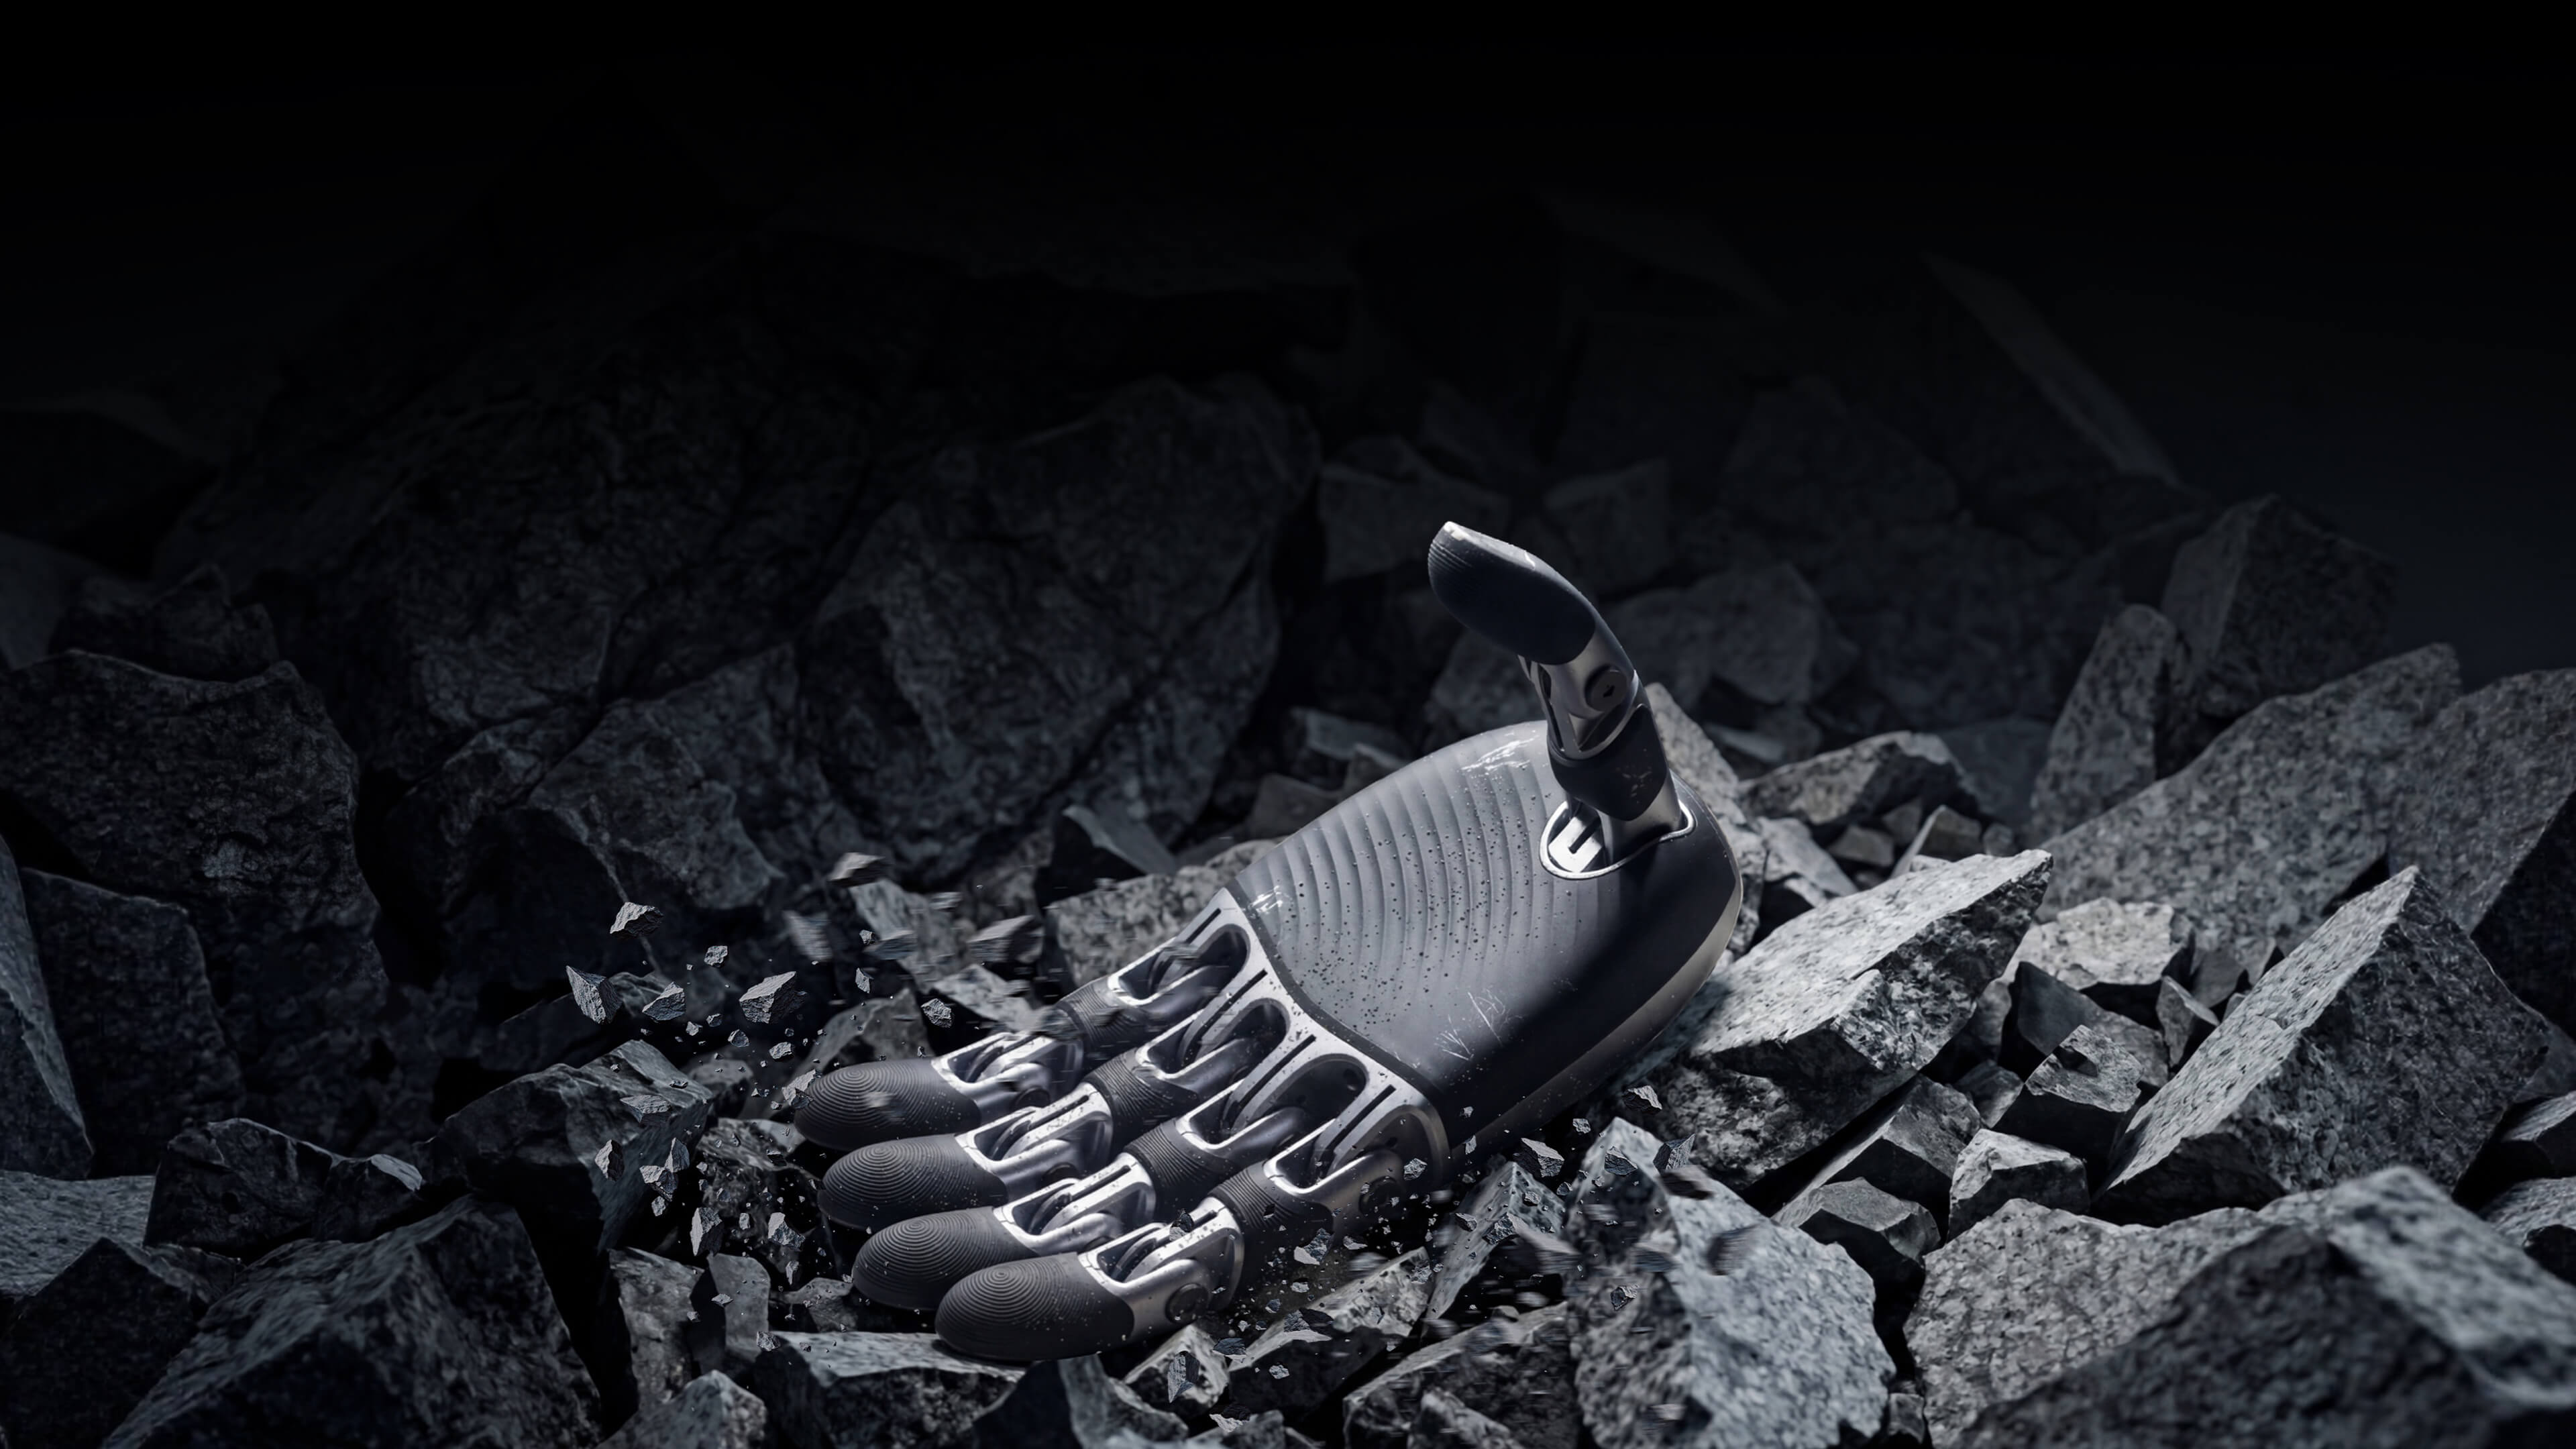 灵巧手
A twenty-DOF fully actuated force-control end effector for high-DOF anthropomorphic manipulation.
Five-finger Fully Actuated Force-control Hand
Four parallel grasping fingers and one opposed thumb create a natural anthropomorphic workspace, built around twenty DOFs, multimodal tactile sensing and real-time software interfaces.
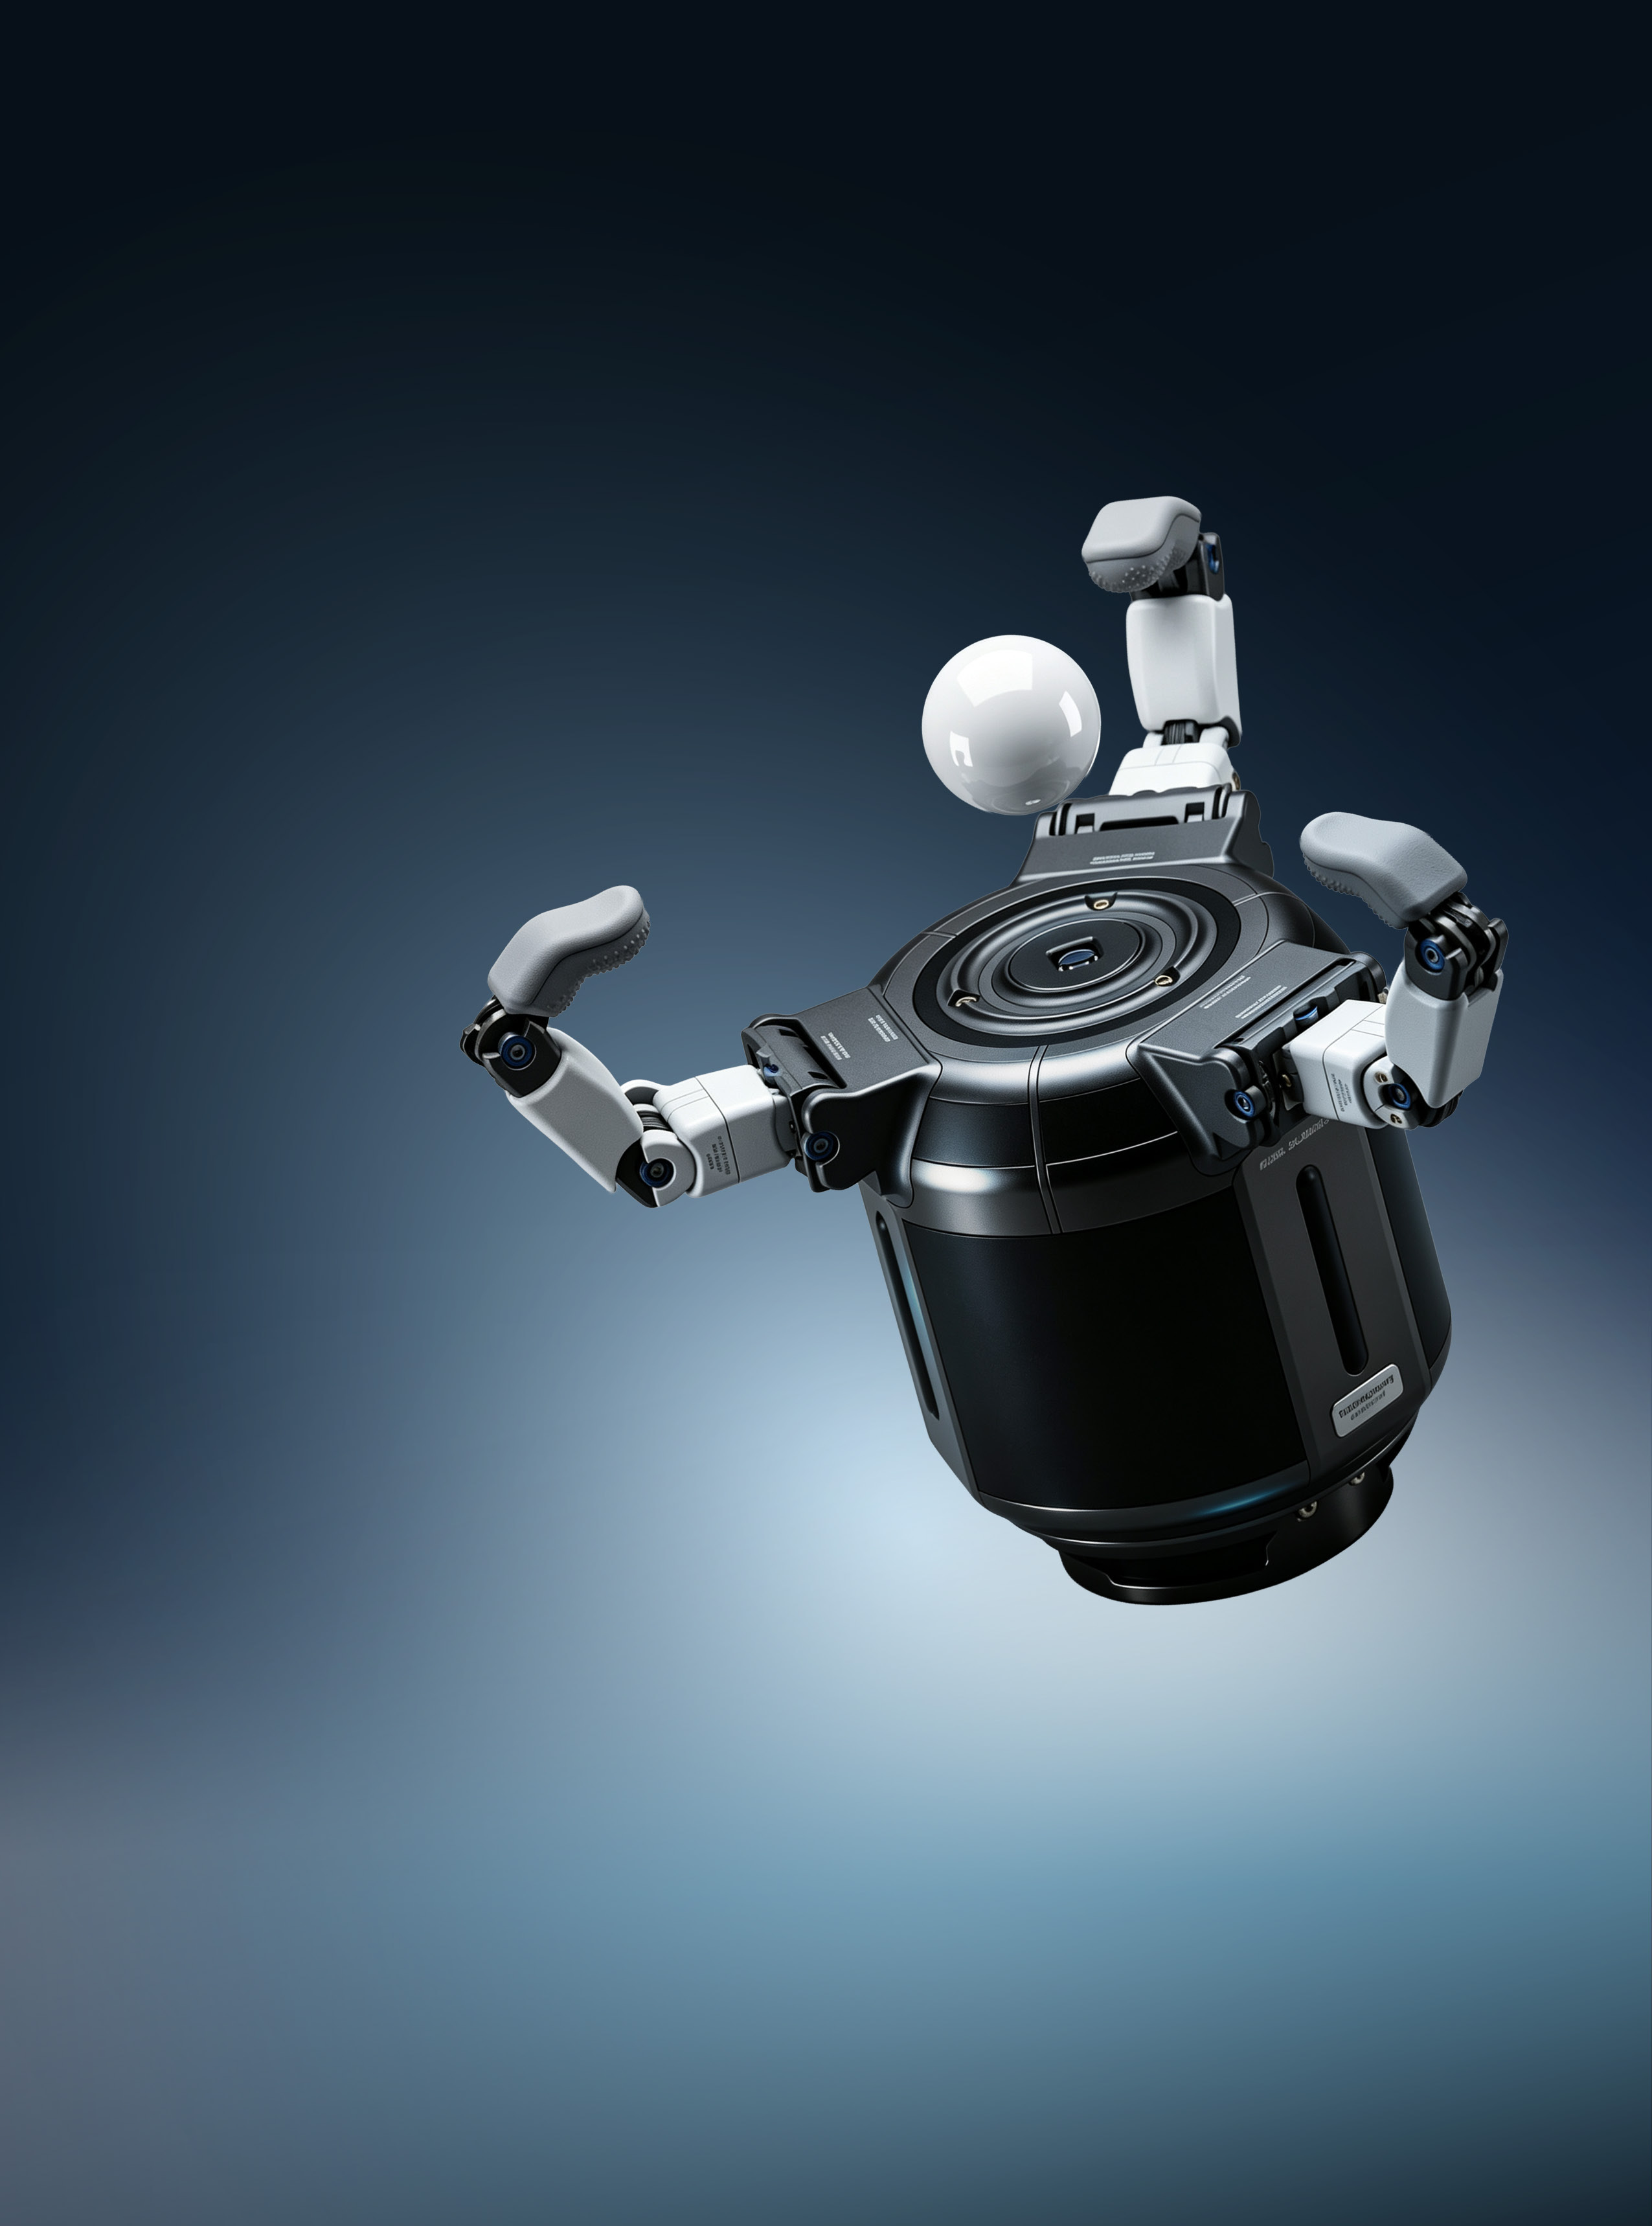 灵巧手
A cost-efficient tendon-driven end effector for flexible grasping, precision assembly and research validation.
Three-finger Tendon-driven Dexterous Hand
A symmetric 120° three-finger layout with three joints and four DOFs per finger balances multi-DOF motion and flexible grasping through tendon drive.